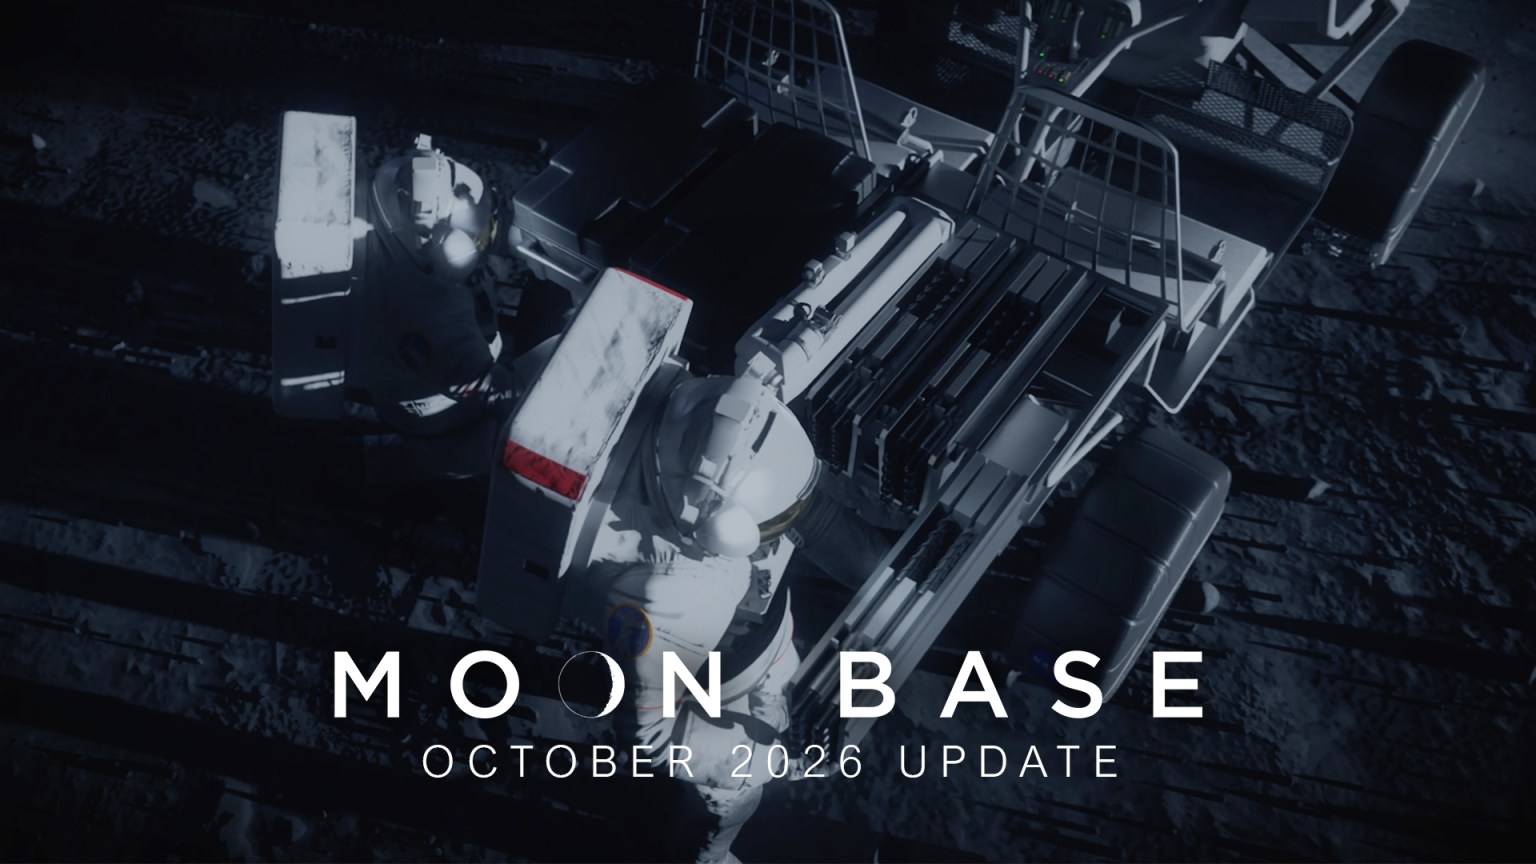
NASA has released a progress update on its Moon Base rovers, detailing the development of both robotic and crewed lunar terrain vehicles that will support surface mobility and scientific exploration on the Moon. The update includes insights into the design, testing, and future deployment of these systems, which are critical for building a sustainable human presence on the lunar surface.
NASA’s VIPER rover, set to launch in 2027, will explore the Moon’s South Pole region to search for water and other resources essential for long-term exploration. After being delivered by a Blue Moon Mark 1 lander, VIPER will travel over 18 miles (30 kilometers) to collect data on the thermal, lighting, and terrain conditions of the area, aiding in the planning of future Moon Base infrastructure.
The VIPER mission will be managed from NASA’s Ames Research Center, where teams are simulating scenarios for the rover’s operations. Currently, VIPER is undergoing final testing at NASA’s Johnson Space Center before being transported to Kennedy Space Center for launch. This data will help inform the development of future mobility systems and resource utilization strategies for the Moon Base.
NASA has also awarded contracts to Astrolab and Lunar Outpost to develop the first phase of crewed lunar terrain vehicles (LTVs) that will be delivered to the Moon ahead of the Artemis missions. These LTVs will be remotely operated from Earth, capable of traversing up to 3.7 miles (6 kilometers) per day and mapping the lunar surface to support future crewed exploration.
Astrolab’s CLV-1 rover, derived from its FLEX architecture, is being tested with NASA astronauts at Axiom Space, where they evaluated the rover’s design and interfaces. A robotic predecessor, FLIP, will be deployed on the Griffin Mission One in late 2026 to test subsystems like tires, batteries, and cameras, which will be used on CLV-1. Astrolab is also set to test its LTV mockups at NASA’s Glenn Research Center in the coming weeks.
Lunar Outpost’s Pegasus LTV, a lighter and more mission-ready version of its Eagle model, is undergoing testing with NASA astronauts at Johnson Space Center. The company has already deployed a robotic rover, MAPP, to the Moon’s South Pole in 2025, which collected data and validated key systems for future LTVs. Lunar Outpost is also planning to test the mobility and traction of its spring mesh tires at NASA Glenn in the near future.
Both Astrolab and Lunar Outpost are on schedule to complete their preliminary design reviews by the end of 2026, with flight-ready hardware expected to be delivered to NASA by the end of 2027. These rovers will support Artemis astronauts in exploring geologically diverse areas of the South Pole, collecting samples, and conducting scientific investigations to further lunar exploration and resource utilization.